mirror of
https://github.com/odriverobotics/ODrive.git
synced 2026-09-17 03:18:59 +08:00
Updated the README.md file
This commit is contained in:
 Harry
@@ -1,9 +1,9 @@
|
||||
# ODrive
|
||||
This project is all about accuratly driving brushless motors, for cheap. The aim is to make it possible to use inexpensive brushless motors in high performance robotics projects.
|
||||
This project is all about accurately driving brushless motors, for cheap. The aim is to make it possible to use inexpensive brushless motors in high performance robotics projects.
|
||||
Like this:
|
||||
[](https://www.youtube.com/watch?v=WT4E5nb3KtY)
|
||||
[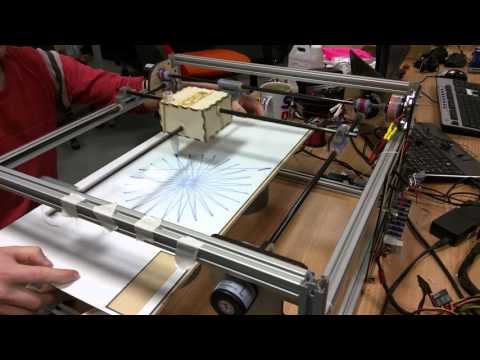](https://www.youtube.com/watch?v=WT4E5nb3KtY)
|
||||
|
||||
This repository contains configuration and analysis scripts that runs on a PC. The other related repositories are:
|
||||
This repository contains configuration and analysis scripts that run on a PC. The other related repositories are:
|
||||
* [ODriveFirmware](https://github.com/madcowswe/ODriveFirmware): Firmware that runs on the board.
|
||||
* [ODriveHardware](https://github.com/madcowswe/ODriveHardware): Circuit board design.
|
||||
|
||||
@@ -14,15 +14,17 @@ There is also [ODriveFPGA](https://github.com/madcowswe/ODriveFPGA), which conta
|
||||
|
||||
It is perfectly fine, and even recommended, to start testing with just a single motor and encoder.
|
||||
Make sure you have a good mechanical connection between the encdoer and the motor, slip can cause disasterous oscillations.
|
||||
All non-power I/O is 3.3v output and 5v tolerant on input, except:
|
||||
All non-power I/O is 3.3V output and 5V tolerant on input, except:
|
||||
|
||||
* GPIO_3 and GPIO_4 are NOT 5v tolerant on ODrive v3.2 and earlier.
|
||||
* GPIO_3 and GPIO_4 are NOT 5V tolerant on ODrive v3.2 and earlier.
|
||||
|
||||
You need one or two [brushless motors](https://hackaday.io/project/11583-odrive-high-performance-motor-control/log/37666-hobby-motors-in-your-robots), [quadrature incremental encoder(s)](https://discourse.odriverobotics.com/t/which-encoders-to-choose/63/2), and a power resistor.
|
||||
|
||||
You need one or two brushless motor(s), qudrature incremental encoder(s), and likely a power resistor.
|
||||
If you are powering from a battery that can absorb the energy from decellerating the load, and you wish to do regenerative breaking, then you do not need a power resistor. If your load is just the motor rotor, and you are testing at low speeds, it may not be required. If you are powering from a power supply, and have a load attached or are running at significant speeds/accelerations, you NEED to connect a power resistor.
|
||||
The power resistor values you need depends on your motor setup, and peak/average decelleration power. A good starting point would be a [0.47 ohm, 50W resistor](https://www.digikey.com/product-detail/en/te-connectivity-passive-product/HSA50R47J/A102181-ND/2056131).
|
||||
|
||||
Wire up the motor phases into the 3-phase screw terminal(s), and the power resistor to the AUX terminal. Wire up the power source (12-24V) to the DC terminal, make sure to pay attention to the polarity. Do not apply power just yet.
|
||||
Wire up the motor phases into the 3-phase screw terminals, and the power resistor to the AUX terminal. Wire up the power source (12-24V) to the DC terminal, make sure to pay attention to the polarity. Do not apply power just yet.
|
||||
|
||||

|
||||
|
||||
Wire up the encoder(s) to J4. The A,B phases are required, and the Z (index pulse) is optional. The A,B and Z lines have 1k pull up resistors, for use with open-drain encoder outputs. For single ended push-pull signals with weak drive current (\<4mA), you may want to desolder the pull-ups.
|
||||
|
||||
|
||||
Reference in New Issue
Block a user