mirror of
https://github.com/odriverobotics/ODrive.git
synced 2026-09-20 06:28:03 +08:00
 Samuel Sadok
da7f719283
Consistent naming makes code autogeneration easier.
This commit does not claim that the exported names of the variables were
more sensible than the in-code names. However changing the exported
names can break external tools and needs to happen in a controlled and
documented way.
114 lines
3.2 KiB
Markdown
114 lines
3.2 KiB
Markdown
# Input Modes
|
|
As of version ###, ODrive now intercepts the incoming commands and can apply filters to them. The old protocol values `pos_setpoint`, `vel_setpoint`, and `current_setpoint` are still used internally by the closed-loop cascade control, but the user cannot write to them directly. This allows us to condense the number of ways the ODrive accepts motion commands. The new commands are:
|
|
|
|
* `<axis>.controller.config.input_mode`
|
|
* `<axis>.controller.input_pos`
|
|
* `<axis>.controller.input_vel`
|
|
* `<axis>.controller.input_current`
|
|
|
|
The Input Modes currently valid are:
|
|
* `INPUT_MODE_INACTIVE`
|
|
* `INPUT_MODE_PASSTHROUGH`
|
|
* `INPUT_MODE_VEL_RAMP`
|
|
* `INPUT_MODE_POS_FILTER`
|
|
* `INPUT_MODE_MIX_CHANNELS`
|
|
* `INPUT_MODE_TRAP_TRAJ`
|
|
* `INPUT_MODE_CURRENT_RAMP`
|
|
* `INPUT_MODE_MIRROR`
|
|
|
|
---
|
|
|
|
## INPUT_MODE_INACTIVE
|
|
Disable inputs. Setpoints retain their last value.
|
|
|
|
## INPUT_MODE_PASSTHROUGH
|
|
Pass `input_xxx` through to `xxx_setpoint` directly.
|
|
|
|
### Valid Inputs:
|
|
* `input_pos`
|
|
* `input_vel`
|
|
* `input_current`
|
|
|
|
### Valid Control modes:
|
|
* `CONTROL_MODE_VOLTAGE_CONTROL`
|
|
* `CONTROL_MODE_CURRENT_CONTROL`
|
|
* `CONTROL_MODE_VELOCITY_CONTROL`
|
|
* `CONTROL_MODE_POSITION_CONTROL`
|
|
|
|
## INPUT_MODE_VEL_RAMP
|
|
Ramps a velocity command from the current value to the target value.
|
|
|
|
### Configuration Values:
|
|
* `<axis>.controller.config.vel_ramp_rate` [cpr/sec]
|
|
* `<axis>.controller.config.inertia` [A/(count/s^2))]
|
|
|
|
### Valid inputs:
|
|
* `input_vel`
|
|
|
|
### Valid Control Modes:
|
|
* `CONTROL_MODE_VELOCITY_CONTROL`
|
|
|
|
## INPUT_MODE_POS_FILTER
|
|
Implements a 2nd order position tracking filter. Inteded for use with step/dir interface, but can also be used with position-only commands.
|
|
|
|

|
|
Result of a step command from 1000 to 0
|
|
|
|
### Configuration Values:
|
|
* `<axis>.controller.config.input_filter_bandwidth`
|
|
* `<axis>.controller.config.inertia`
|
|
|
|
### Valid inputs:
|
|
* `input_pos`
|
|
|
|
### Valid Control modes:
|
|
* `CONTROL_MODE_POSITION_CONTROL`
|
|
|
|
## INPUT_MODE_MIX_CHANNELS
|
|
Not Implemented.
|
|
|
|
|
|
## INPUT_MODE_TRAP_TRAJ
|
|
Implementes an online trapezoidal trajectory planner.
|
|
|
|

|
|
|
|
### Configuration Values:
|
|
* `<axis>.trap_traj.config.vel_limit`
|
|
* `<axis>.trap_traj.config.accel_limit`
|
|
* `<axis>.trap_traj.config.decel_limit`
|
|
* `<axis>.controller.config.inertia`
|
|
|
|
### Valid Inputs:
|
|
* `input_pos`
|
|
|
|
### Valid Control Modes:
|
|
* `CONTROL_MODE_POSITION_CONTROL`
|
|
|
|
## INPUT_MODE_CURRENT_RAMP
|
|
Ramp a current command from the current value to the target value.
|
|
|
|
### Configuration Values:
|
|
* `<axis>.controller.config.current_ramp_rate`
|
|
|
|
### Valid Inputs:
|
|
* `input_current`
|
|
|
|
### Valid Control Modes:
|
|
* `CONTROL_MODE_CURRENT_CONTROL`
|
|
|
|
## INPUT_MODE_MIRROR
|
|
Implements "electronic mirroring". This is like electronic camming, but you can only mirror exactly the movements of the other motor, according to a fixed ratio
|
|
|
|
[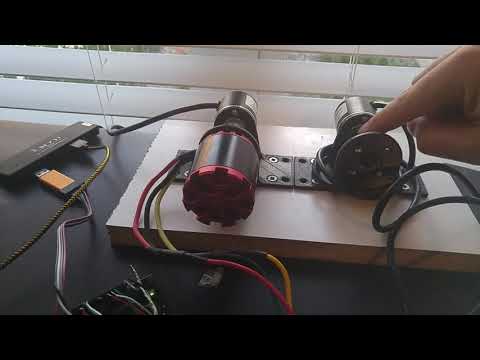](http://www.youtube.com/watch?v=D4_vBtyVVzM "Example Mirroring Video")
|
|
|
|
### Configuration Values
|
|
* `<axis>.controller.config.axis_to_mirror`
|
|
* `<axis>.controller.config.mirror_ratio`
|
|
|
|
### Valid Inputs
|
|
* None. Inputs are taken directly from the other axis encoder estimates
|
|
|
|
### Valid Control modes
|
|
* `CONTROL_MODE_POSITION_CONTROL`
|